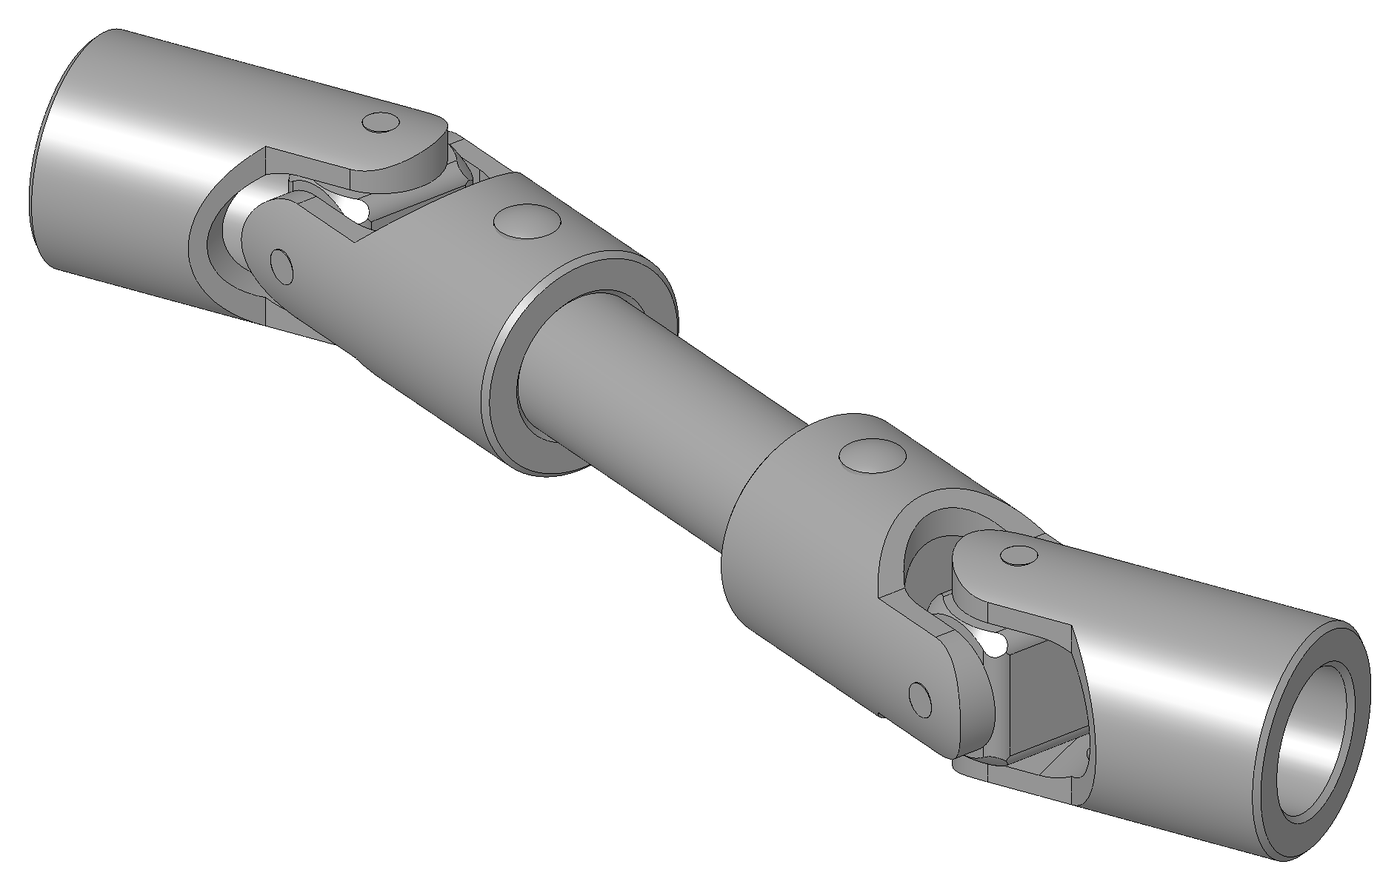

Universal Joint
说明
Make the cross
Make the cross
Four arms at 90 degrees, all the same length from centre. This part decides everything.
- Cut two 70 mm lengths of 25 mm aluminium round bar, or use 20 × 20 mm square bar for easier clamping.
- Mark the exact centre of each and cross-drill one 8.1 mm through, square to the bar.
- Cut a half-lap in each so the two cross at their centres and sit flush.
- Join them with a single M4 × 30 socket head cap screw through the lap, M4 flat washer × 2, M4 nylon insert lock nut × 1.
- Check with the caliper that all four arm ends are equidistant from the centre, within 0.2 mm.
此步骤所需材料:
 铝圆棒1 个
 内六角圆柱头螺钉1 个
 平垫圈2 个
 尼龙自锁螺母1 个
所需工具:
 钢锯弓配锯条
 台虎钳
 充电式电钻
 钻头套装
 锉刀套装
 6 英寸数显卡尺
 中心冲
Cut the two yokes
Cut the two yokes
Each yoke is a U that straddles one pair of cross arms.
- Cut two strips 120 × 30 mm from 6 mm aluminium flat bar.
- Bend each into a U with 45 mm between the inside faces, or make each yoke from two separate arms bolted to a hub if bending 6 mm is beyond your vise.
- Drill both arms of each yoke together at 5.0 mm so the holes are coaxial.
- Deburr every hole.
Drilling both arms in one setup is what makes the axis straight. Drill them separately and the two holes will not line up; the cross then binds at one end of its swing and the joint feels notchy rather than smooth.
If you bolt rather than bend, use two M4 × 16 socket head cap screws per yoke into the hub with M4 flat washers, and check squareness with the combination square before final tightening.此步骤所需材料:
 铝扁条1 个内六角圆柱头螺钉4 个平垫圈8 个
所需工具:
台虎钳充电式电钻钻头套装 组合角尺锉刀套装
Assemble the joint and mount the shafts
Assemble the joint and mount the shafts
Two yokes, one cross, four pivots — and the two yokes must end up 90 degrees apart.
- Fit yoke 1 over one pair of cross arms using M5 × 30 socket head cap screws × 2 as pivot pins, with M5 flat washers × 4 and M5 hex nuts × 2.
- Fit yoke 2 over the other pair the same way — it will naturally sit at 90 degrees to the first.
- Mount each yoke on a shaft of 25 mm aluminium round bar.
- Support each shaft in a 608 bearing set into a plywood pillow block, so the input runs level and the output can be angled.
- Make the output block's mounting holes SLOTTED so you can set 0, 15 and 30 degree angles.
此步骤所需材料:
铝圆棒1 个 波罗的海桦木胶合板1 张平垫圈8 个
 六角螺母4 个
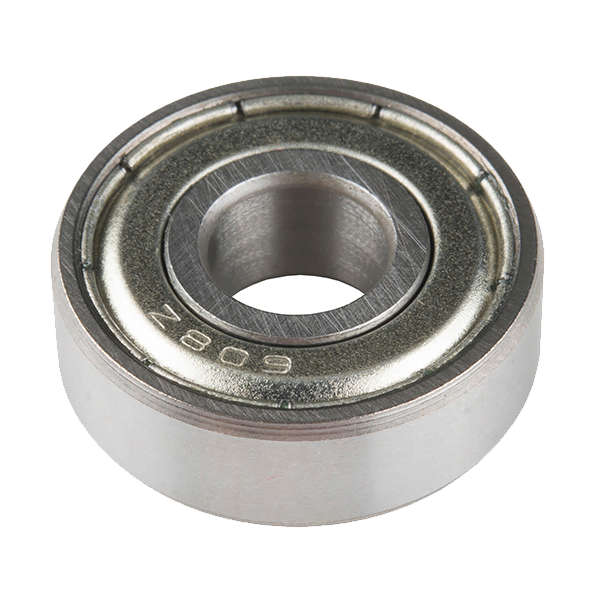 Ball Bearing - Non-Flanged (8mm Bore, 22mm OD)2 个
所需工具:
 内六角扳手组充电式电钻钻头套装
 钢丝锯(曲线锯)6 英寸数显卡尺
Measure the velocity error you were told about
Measure the velocity error you were told about
This is the step that turns a familiar part into an understood one.
- Fit paper protractor discs to both shafts and align both at zero.
- Set the output at 0 degrees. Turn the input in 30 degree steps and record the output angle each time.
- Set 15 degrees and repeat. Then 30 degrees.
- For each run, plot output angle minus input angle.
此步骤所需材料:
波罗的海桦木胶合板1 包所需工具:
组合角尺6 英寸数显卡尺The two-joint cure, and history
The two-joint cure, and history
The standard fix is not a better joint — it is a second one. Put two universal joints in a driveshaft with equal operating angles and the yokes of the intermediate shaft in the same plane, and the second joint's error exactly cancels the first's. The output then turns at constant velocity even though neither joint does individually. Get the phasing wrong by 90 degrees and the errors ADD instead, which is a real and common cause of driveline vibration.
History. Gerolamo Cardano described the gimbal suspension in 1545 — hence Cardan joint — though as a mounting for compasses and lamps rather than a drive. Robert Hooke built and analysed the joint in the 1670s and identified the velocity variation, which is why it is also called a Hooke joint and why the error is sometimes called Hooke's coupling error.
Where each approach fits: a universal joint handles ANGULAR misalignment cheaply and takes real torque, at the cost of velocity error that grows with angle. An Oldham coupling handles PARALLEL offset at constant velocity but no angle at all. A true constant-velocity joint — the Rzeppa design in every front-wheel-drive car — solves both at once and costs far more to make. Three answers to misalignment, and the right one depends entirely on which kind of misalignment you have.
Why tractors are dangerous here: a power take-off shaft runs a universal joint at whatever angle the implement sits, and the velocity error becomes torque pulsation. That is a genuine mechanical reason PTO guards exist, on top of the obvious one.
材料
10- 1 个占位符
- 5 个占位符
- 10 个占位符
- 1 个占位符
- 1 个占位符
- 1 包占位符
- 8 个占位符
- 4 个占位符
- $1.27
- 1 张占位符
所需工具
10- 占位符
- 占位符
- 1 vendor sell this, none ship to you yet占位符
- 占位符
- 占位符
- 占位符
- 占位符
- 占位符
- 占位符
- 占位符
CC0 公共领域
此蓝图以 CC0 协议发布。你可以自由复制、修改、分发和使用此作品,无需征得许可。
通过购买蓝图中的产品支持创客,他们将获得 创客佣金 (由供应商设定),或创建此蓝图的新版本并将其作为连接包含在你自己的蓝图中以分享收入。