ARTE
BELLEZA Y BIENESTAR
ARTESANÍA
CULTURA E HISTORIA
ENTRETENIMIENTO
MEDIO AMBIENTE
COMIDA Y BEBIDAS
INGENIERÍA INVERSA
CIENCIAS
DEPORTES
TECNOLOGÍA
TECNOLOGÍA VESTIBLE

Bode: Gain, Phase and What Feedback Costs
Nyquist's criterion answers a yes-or-no question about a loop you have already built. It does not tell you what to change, and at Bell Labs in the 1930s that left designers measuring amplifier after amplifier without a way to steer the next one.
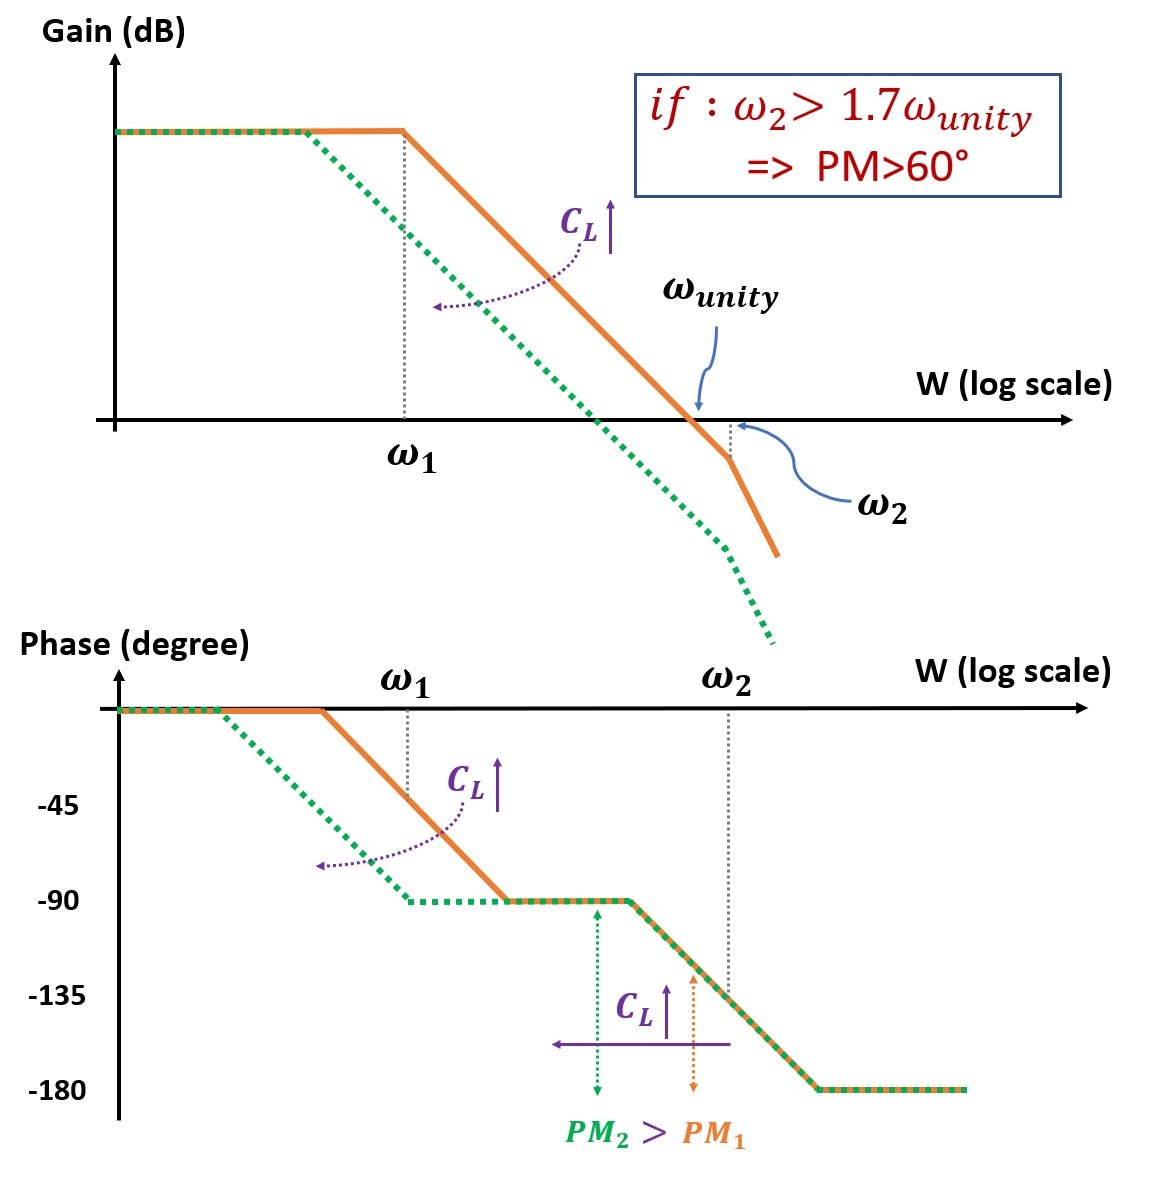
Hendrik Bode's answer, worked out through the 1930s and published as a book in 1945, is that for an ordinary minimum-phase network the phase is not free. It is determined by how fast the gain is falling: a slope of twenty decibels per decade goes with ninety degrees of lag, forty with a hundred and eighty. The stability question therefore becomes a question about a SLOPE, and the design rule that runs all of classical control falls straight out - cross through unity gain at twenty decibels per decade, because forty means a hundred and eighty degrees, and a hundred and eighty degrees at unity gain is an oscillator.
The deeper result is the one that has no workaround. For a stable loop with no right-half-plane poles that falls off faster than one over frequency, the integral of the log of the sensitivity over all frequencies is exactly zero. Sensitivity below one is where feedback is helping you; the integral says every decibel of help at one frequency is paid for by a decibel of harm at another. Engineers call it the waterbed: press it down here and it comes up there.
That is why the design decisions in this blueprint are all about WHERE, never how much. Turning the gain down, adding a dominant pole, adding a lead network and buying a faster plant all reach the same phase margin and cost completely different things - accuracy everywhere, speed, noise at the actuator, or money.
Avanzado
3 hours
Instrucciones
1
1
Measure a slope and a phase together
Measure a slope and a phase together
Build a two-stage RC low-pass with a buffer between the sections - 10k and 10 nF, then 10k and 1 nF - and sweep it with the generator, recording amplitude and phase per decade.
Plot gain in decibels against log frequency and phase underneath. Where the gain falls at 20 dB per decade the phase sits at 90 degrees; where both sections are working it is 40 and 180. The two plots are not independent measurements of the same thing.
Materiales para este paso:
 Kit de resistencias de 1/4 W1 kit
 Kit de condensadores cerámicos1 kit
 Papel milimetrado6 hojas
Herramientas necesarias:
 Breadboard - Classic
 Generador de señales DDS
 Osciloscopio digital
 Amplificador operacional JFET TL072
 Juego de lápices de grafito
2
2
Buy phase margin two different ways
Buy phase margin two different ways
Close a loop around the network with an op-amp until it rings, then reduce the loop gain until the ringing dies. Note the closed-loop accuracy you have lost.
Put the gain back and instead add a single slow lag - 100k and 1 uF - ahead of it. The ringing goes again, the DC accuracy comes back, and the loop is now visibly slower. Same margin, different bill.
Materiales para este paso:
Kit de resistencias de 1/4 W1 kit Kit de condensadores electrolíticos1 kit
Herramientas necesarias:
Amplificador operacional JFET TL072Breadboard - ClassicOsciloscopio digitalGenerador de señales DDS3
3
Slope against phase, the waterbed, and four compensators
Slope against phase, the waterbed, and four compensators
Cargando el cuaderno de Jupyter…
Herramientas necesarias:
 Ordenador de sobremesa
4
4
Compendium: when the slope rule stops being true
Compendium: when the slope rule stops being true
The gain-phase relation holds only for MINIMUM-PHASE systems: no poles or zeros in the right half plane and no pure time delay. Two common things break it. A transport delay - a conveyor, a pipeline, sound crossing a room, a network hop - adds phase without touching the gain at all, so no amount of reshaping the magnitude plot buys it back and the only cure is to cross over below where the delay has eaten the margin. A right-half-plane ZERO does something stranger: it also adds lag while the gain falls, and it makes the output go the WRONG WAY first. A boiler whose drum level drops when you add cold water, or an aircraft that sinks before it climbs when the elevator comes up, are both this, and both impose a hard ceiling on how fast any controller may be allowed to act.
The integral has a sharper version for those cases. With an unstable open-loop pole at p it is no longer zero but pi times p, so an inherently unstable plant does not merely need feedback - it needs a fixed quantity of amplification-somewhere that grows with how unstable it is. That is the mathematics behind a fact every pilot of a relaxed-stability aircraft relies on: the machine can be made to fly beautifully and can never be made insensitive.
Materiales
4- Marcador de posición
- Marcador de posición
- 6 hojasMarcador de posición
- Marcador de posición
Herramientas requeridas
6- Breadboard - Classic10% de comisiónMX$163.18
- Marcador de posición
- Osciloscopio digital10% de comisiónMagento Legacy Storeships internationallyMarcador de posición
- Marcador de posición
- Marcador de posición
- Marcador de posición
Blueprints relacionados
Estos blueprints comparten conocimiento — técnicas, materiales o principios

CC0 Dominio público
Este Blueprint se publica bajo CC0. Eres libre de copiar, modificar, distribuir y usar este trabajo para cualquier propósito, sin pedir permiso.
Apoya al Maker comprando productos a través de su Blueprint, donde gana una Comisión del Maker establecida por los vendedores, o crea una nueva iteración de este Blueprint e inclúyela como conexión en tu propio Blueprint para compartir ingresos.